STMicroelectronics (STM32G4x, STM32F4x, STM32F7x, STM32H7x) 1. From Lightweight RTOS to Modern Embedded Platform: FreeRTOS vs. Zephyr 2. Introduction to Zephyr RTOS: Architecture and Features 3. Zephyr Kconfig: Application Configuration and Options 4. Zephyr Devicetree: Hardware Description and Configuration Back to top of the page
Category: Control
TI C2000: Introduction to TI C2000 Core Board V1.3
TI C2000 Real-Time Microcontroller: Control, Sensing, and Communication TI Dual-core TMS320F28375D Core Board V1.3 TMS320F28375D Core Board V1.3 GPIO and Peripheral Muxing Comparison between LAUNCHXL-F28377S/F28379D and Core Board V1.3 TI Dual-core TMS320F28375D Core Board V1.3 Dimension: 55 mm x 55 mm CPUs: 2× C28x (200 MHz each) CLAs: 2× Control Law Accelerator (200 MHz each)…
Embedded Communication Interfaces
Back to top of the page
Yocto Project: Create a Custom Embedded Linux
Back to top of the page
STM32 Microcontroller and FreeRTOS Development
STMicroelectronics (STM32G4x, STM32F4x, STM32F7x, STM32H7x) 1. Introduction to FreeRTOS: System Architecture and Execution Model 2. FreeRTOS Scheduler: Preemption, Time Slicing, and Deterministic Scheduling 3. Task Management: Task Creation, States, Priorities, and Context Switching xTaskCreate() xTaskCreateStatic() vTaskDelete() xTaskGetHandle() xTaskGetIdleTaskHandle() xTaskGetCurrentTaskHandle() vTaskPrioritySet() uxTaskPriorityGet() vTaskSuspend() vTaskResume() xTaskResumeFromISR() vTaskDelayUntil() xTaskGetTickCount() xTaskGetTickCountFromISR() vTaskSetApplicationTaskTag() xTaskGetApplicationTaskTag() SetThreadLocalStoragePointer() GetThreadLocalStoragePointer() pcTaskGetName() uxTaskGetNumberOfTasks() vTaskGetInfo() uxTaskGetSystemState()…
TI C2000 Real-Time Microcontroller: Control, Sensing, and Communication
TI C2000 Real-time Microcontroller (TMS320F28x7x / F2837xx / F2838x) TI C2000 C28x Microcontroller with FreeRTOS TI C2000 C28x Microcontroller with Simulink Embedded Coder 1. Introduction to TI C2000 Core Board V1.3 TI Dual-core TMS320F28375D Core Board V1.3 TMS320F28375D Core Board V1.3 GPIO and Peripheral Muxing Comparison between LAUNCHXL-F28379D and Core Board V1.3 2. TI C2000…
Vehicle Interface & PACMod2
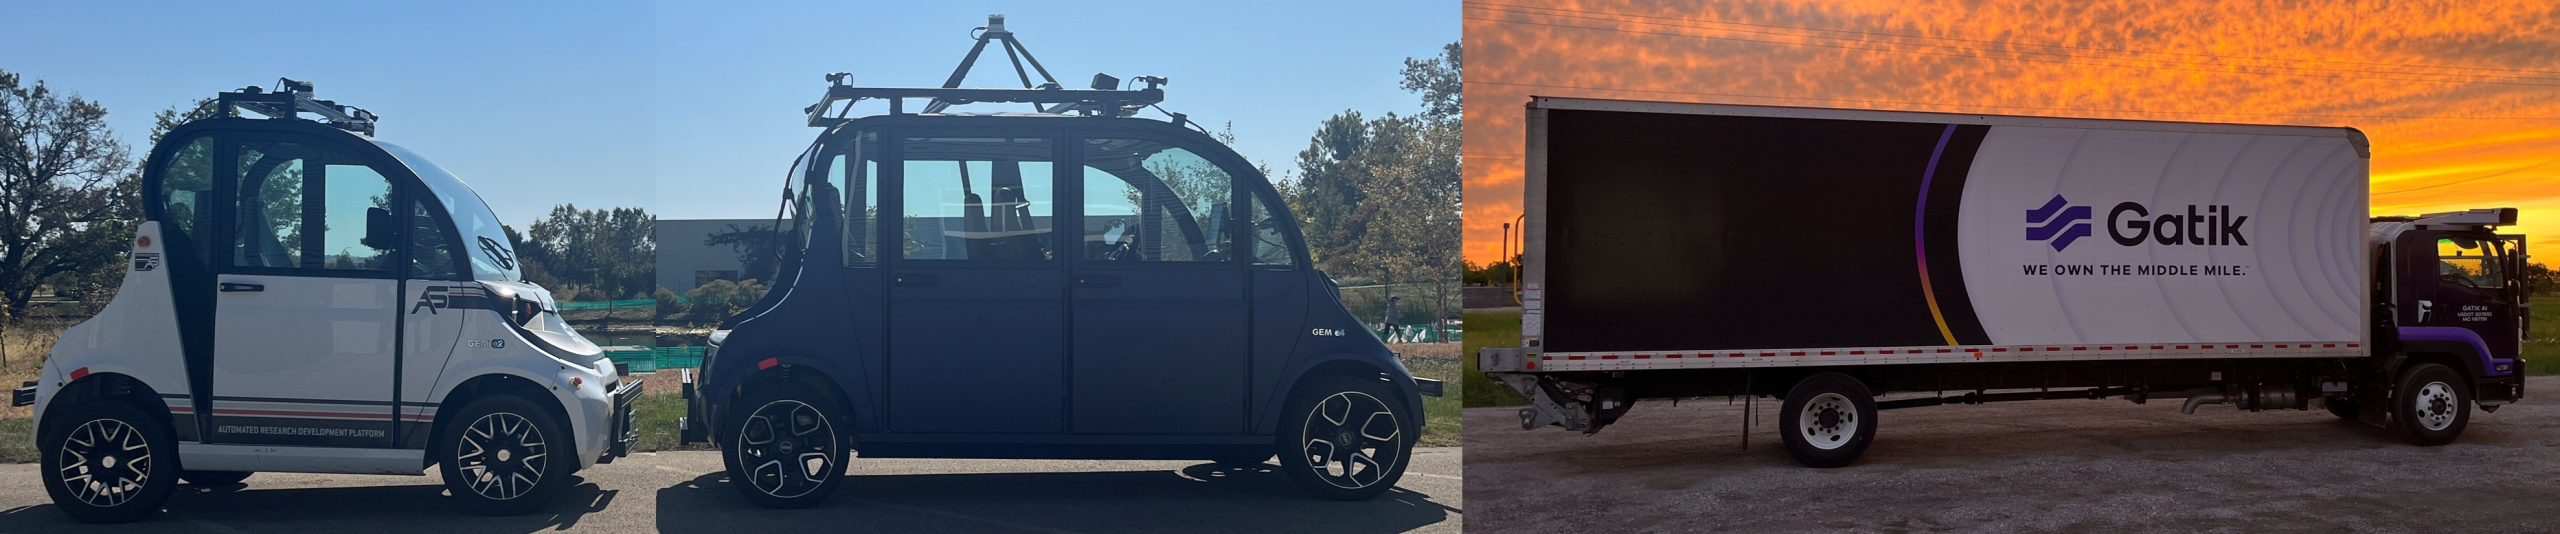
Stay tuned for future updates! The Vehicle Interface component provides an interface between Autoware and a vehicle that passes control signals to the vehicle’s drive-by-wire system and receives vehicle information that is passed back to Autoware. Vehicle Lateral Interface Longitudinal Interface Polaris GEM Vehicle steering angle/rate accel/brake pedal position Lexus steering angle accel/brake pedal position…
Vehicle Accel/Brake Calibration
Stay tuned for future updates! Acceleration and Brake Map Calibration Raw Vehicle Command Converter Steer Offset Estimator Reference Acceleration and Brake Calibration (Polaris GEM Vehicles) accel_brake_map_calibrator Raw Vehicle Command Converter (Polaris GEM Vehicles) Steer Offset Estimator (Polaris GEM Vehicles) Reference [1] Autoware Universe Documentation , Link [2] Lochrie, Gabrielle, et al. “Anti-windup recursive least squares…
Real-time Control Module for HIL
I developed a real-time control module (a.k.a. simplified dSPACE MicroAutoBox or Speedgoat target machine) using TI C2000 microcontrollers for hardware-in-the-loop (HIL) applications in electric vehicles, utilizing both CAN and Ethernet interfaces. The system architecture assigns one CPU and CLA group to handle low-level control tasks such as steering and motor actuation of the gas and…
Dynamics & Control
Stay tuned for future updates! Pure Pursuit Lateral Controller (Kinematic Bicycle Model) Stanley Lateral Controller (Kinematic/Dynamic Bicycle Model) LQR Tracker with Feed Forward Term (Dynamic Bicycle Model) Model Predictive Control (Dynamic Bicycle Model) Coming more, stay tuned for future updates! Reference Vehicle Bicycle Model Kinematic Models: Kinematic models are simplifications of dynamic models that ignore…